Umer Farooq

AI researcher, computer vision and embedded AI

I build models that help vehicles read the road. My MS AI thesis detects and tracks motorcycles and rickshaws in dense traffic and warns before a collision. My next focus is embedded AI, and I am open to research collaboration on it.

Get in touch

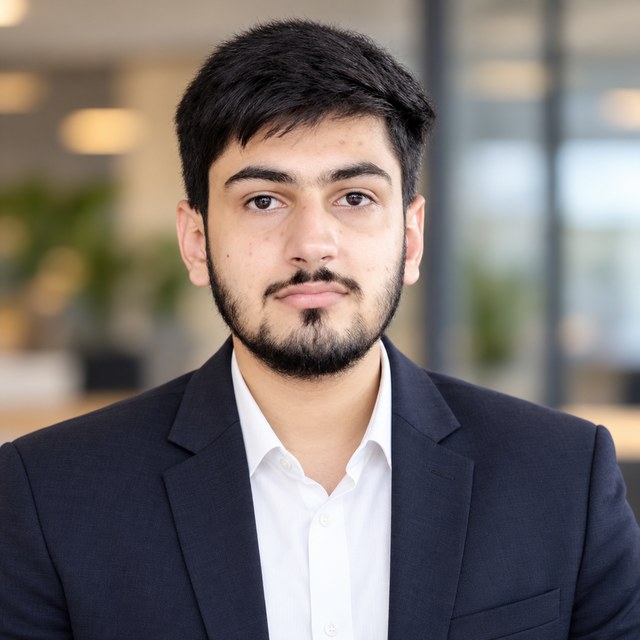
Portrait of Umer Farooq

Research

Rashid Liaquat and I work on both projects together. We each write our own thesis. The papers and products are shared, with first authorship alternating between us.

Motorcycle-Aware Collision Warning

MS thesis project, Joint work with Rashid Liaquat, In progress

Detection and tracking of motorcycles and rickshaws in dense traffic, with a collision warning layer on top.

Pipeline: Record, Annotate, Detect, Track, Estimate, Warn.

Object Detection, Tracking, Road Safety

Details
  1. Record. Road video from a stabilized camera
  2. Annotate. Boxes on motorcycles and rickshaws
  3. Detect. A detector finds them in each frame
  4. Track. Each vehicle keeps its identity across frames
  5. Estimate. Time to collision from distance and speed
  6. Warn. Alert when the time falls below a safe limit
Problem
Motorcycles and rickshaws weave through dense traffic and are often missed by systems built for cars and lanes.
Approach
Supervised detection and tracking of motorcycles and rickshaws, then estimation of time to collision to trigger a warning before a risky situation develops.
Data
Road video from a phone camera, annotated manually with bounding boxes. A gimbal is used to keep footage stable.
Status
In progress. No results are claimed yet.
My MS thesis (in progress)
Annotated road video, detection and tracking of motorcycles and rickshaws, and time-to-collision estimation.
Research paper (planned)
A paper by Umer Farooq (first author) and Rashid Liaquat (second author) on motorcycle-aware collision warning in dense, mixed traffic, with results on locally collected data.
Joint product (planned)
A collision warning aid for riders and drivers that works in mixed traffic like Pakistan's.
Self-Supervised Speed Breaker & Pothole Anticipation

Joint project, Rashid Liaquat's MS thesis, In progress

Predicts unmarked speed breakers and potholes before impact using a phone's camera, GPS and motion sensors. Training labels come from the vehicle's own response to the road, so no manual labeling is needed.

Pipeline: Record, Detect the event, Label, Extract frames, Train, Anticipate.

Computer Vision, Self-Supervised Learning, Sensor Fusion

Details
  1. Record. Phone camera, GPS and IMU on a rigid mount
  2. Detect the event. GPS speed dip plus accelerometer spike; gyroscope confirms
  3. Label. The vehicle's response marks the bump or pothole
  4. Extract frames. Video from 2 to 3 seconds before the event
  5. Train. A lean vision model learns what the road looks like before a hit
  6. Anticipate. Warn before impact and add the spot to a hazard map
Problem
Many speed breakers and potholes on Pakistani roads are unmarked and unmapped, so drivers and navigation apps cannot see them coming.
Approach
The vehicle's own response is used as the label. A dip in GPS speed together with a spike in the accelerometer marks a road event, and the gyroscope confirms it. Video frames from 2 to 3 seconds before the event are then extracted and used to train a lean vision model that recognises the road ahead.
Data
A phone fixed rigidly to the vehicle records camera video, GPS and IMU readings (accelerometer and gyroscope). A rigid mount is required, because a gimbal would remove the vibration signal the labels depend on.
Why it matters
No manual labeling is needed, and the model learns from local road conditions instead of foreign datasets.
Status
Data collection and sensor calibration are the next steps. No results are claimed yet.
Rashid's MS thesis (in progress)
Data collection with a rigidly mounted phone, sensor calibration, self-labeling pipeline, and the vision model.
Research paper (planned)
A paper by Rashid Liaquat (first author) and Umer Farooq (second author) on self-supervised road-hazard anticipation using vehicle response as the label, aimed at a computer vision or intelligent transport venue.
Joint product (planned)
A rider or fleet safety device: a small sensor unit with a GPS hazard map that warns before known bumps, built on the thesis models.

Current focus

Embedded AI

My next focus is embedded AI: models that run on small, low-power hardware right on the vehicle, without needing the internet.

Why on the device. A collision warning is only useful if it arrives in time. Sending video to a server is too slow for a rider on a bike, so the model has to live on the device.

How it connects to my thesis. My thesis, motorcycle-aware collision warning, is built around this. The plan is to detect and track motorcycles and rickshaws, estimate time to collision, and move a lean model onto small hardware with a short warning to the rider.

Planned. Data collection and annotation come first; hardware choices follow what the data shows.

Projects

The first three projects were done jointly with Rashid Liaquat; each notebook is open in our joint repository, lessons-learned, where I contributed. Figures come from the final run saved in each notebook.

Plant Disease Classification with Vision Transformer

Project, Joint work with Rashid Liaquat, Completed

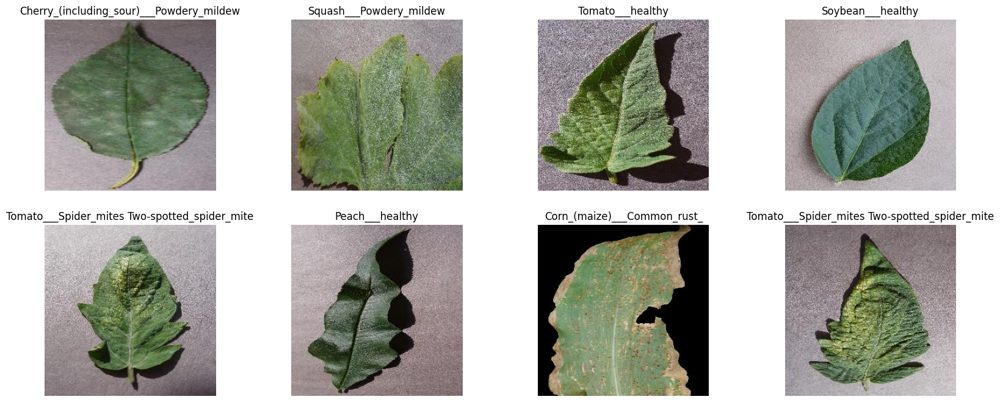
Classifies leaf images into 38 classes from the PlantVillage dataset using a Vision Transformer with transfer learning in PyTorch and Hugging Face Transformers.

92.27% validation accuracy

Vision Transformer, Transfer Learning, PyTorch

Eight sample leaf images from PlantVillage, each labeled with its plant and disease class
Sample leaves from PlantVillage, with class labels.

Goat Health Classification (CRNN from Scratch)

Project, Joint work with Rashid Liaquat, Completed

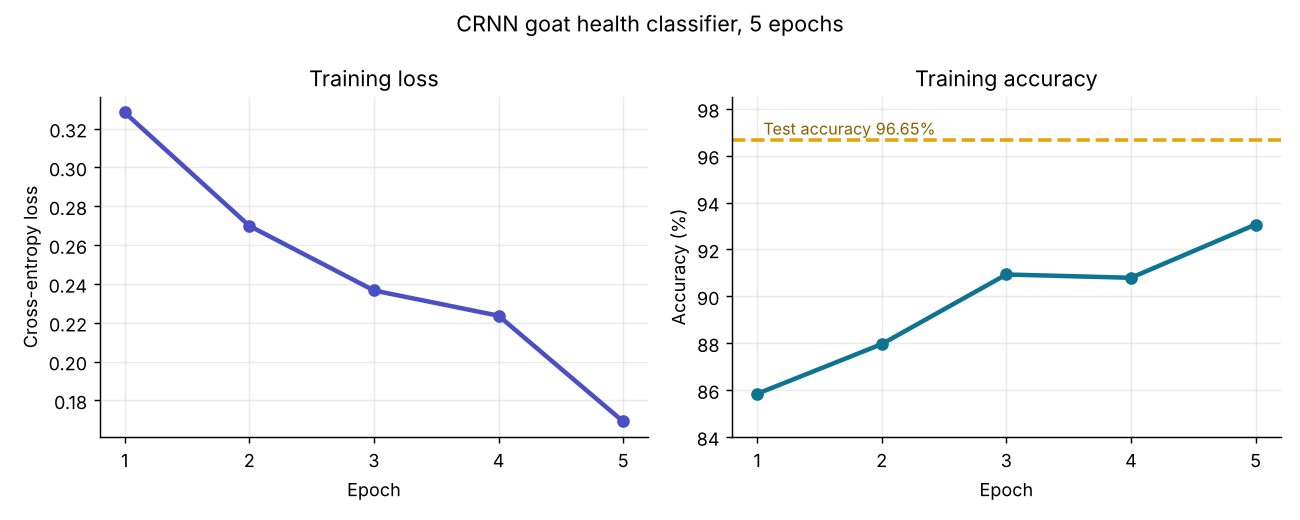
Separates healthy from unhealthy goats using a CNN + LSTM (CRNN) model built from scratch in PyTorch, trained on 742 images and tested on 186.

93.06% train accuracy96.65% test accuracy5 epochs

CNN, RNN, PyTorch

Line charts of training loss falling and training accuracy rising over 5 epochs, with the test accuracy shown as a dashed line
Training loss and accuracy over 5 epochs, with the final test accuracy.

Fruit and Vegetable Classification with CNN

Project, Joint work with Rashid Liaquat, Completed

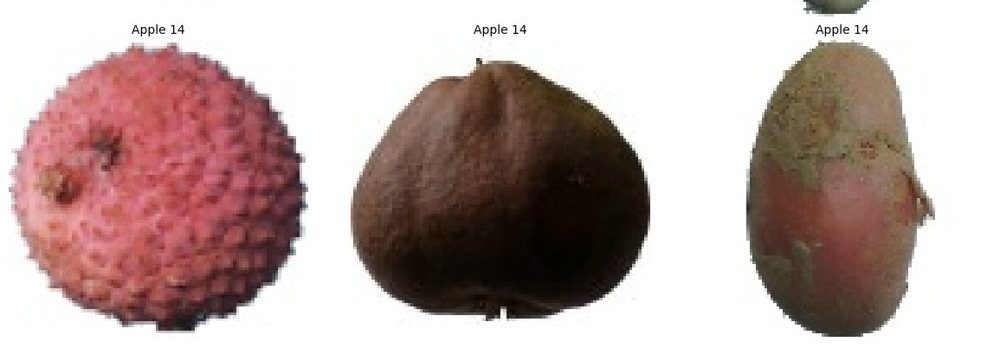
Classifies 240 fruit and vegetable classes from the Fruits-360 dataset (100x100 images) with a CNN in PyTorch.

80.51% train accuracy95.05% test accuracy5 epochs

CNN, PyTorch, Image Classification

Three sample fruit images from Fruits-360 on white backgrounds
Sample images from Fruits-360.

NutriSelect

Mobile app, Completed

A Flutter app that helps users find and explore nutritious products, built with Firebase.

Flutter, Firebase, Mobile development

Skills

Deep learning. PyTorch, CNN, CRNN, Vision Transformer, Image classification.

Road-safety vision. Object detection, Multi-object tracking, Time-to-collision estimation.

Mobile. Flutter, Firebase.

Tools. Python, Jupyter and Colab, Git and GitHub.

Currently learning. Embedded AI, Model deployment on small devices.

Where I can contribute

  • Research collaboration. Joining a research team on computer vision, detection and tracking, or road safety, from literature review and experiments to co-authoring papers.
  • Image classification prototypes. Building and evaluating CNN, CRNN and Vision Transformer classifiers in PyTorch.
  • Mobile apps. Building Flutter apps with a Firebase backend.

About

I am an MS AI student at Superior University, Lahore. My work so far covers image classification with CNNs, CRNNs and Vision Transformers, and a Flutter and Firebase mobile app. I am now moving into object detection, tracking and embedded AI for road safety.

MS Artificial Intelligence, Superior University, Lahore. Started in Fall 2025. Thesis supervisor: Dr. Arfan Jaffar (Professor, Superior University). Co-supervisor and mentor: Talha Nadeem (PhD in AI, AHOY).

Contact

I am open to research collaboration, especially on embedded and edge-based AI, and to AI and machine learning internships. If you have a project or an opening, send me a message.

LinkedIn
linkedin.com/in/umer-farooq-b71a95300

Message on LinkedIn